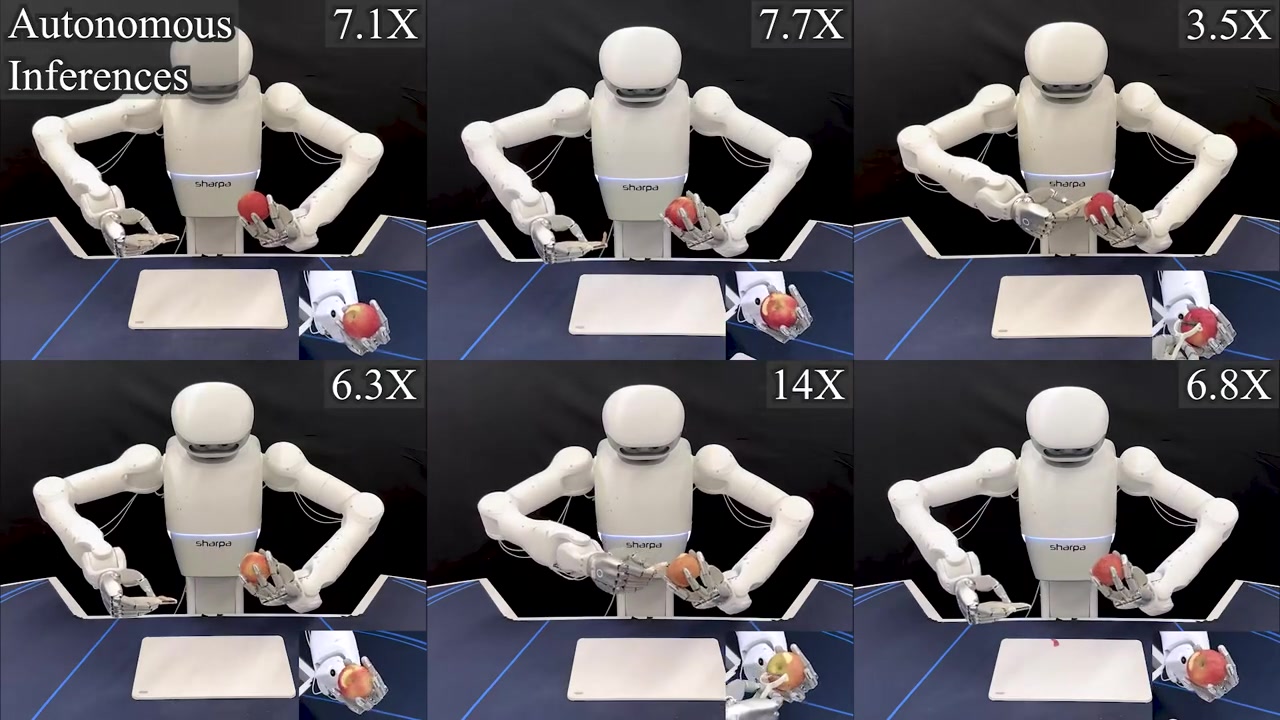
Connecting learned hand skills to a VLA
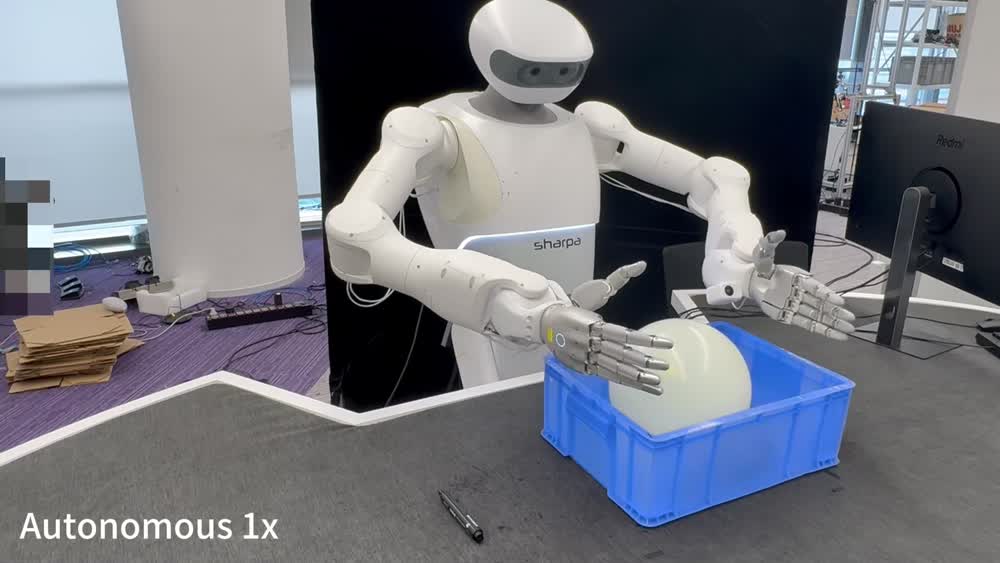
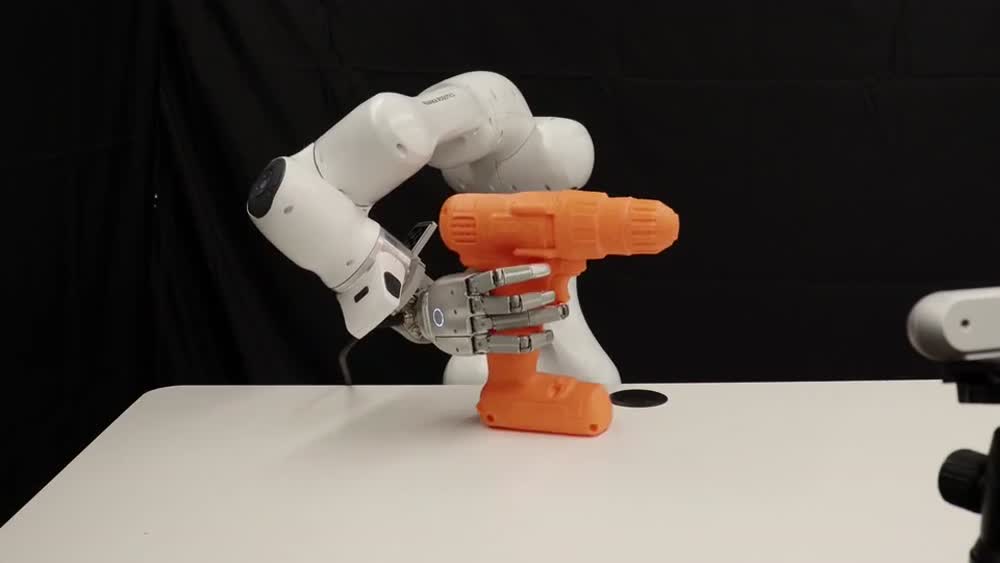
An RL-trained in-hand copilot assists both human data collection and robot execution. MoDE-VLA brings force and tactile feedback into a vision-language-action model for bimanual tasks.
RoboticsUniversity of Hong KongSharpa
Learning to see, feel,
and interact with the world.
I'm a researcher at Sharpa, working on dexterous manipulation and tactile robot learning. I received my Ph.D. in Computer Science from the University of Hong Kong.
My research builds on years of work in nonlinear optimization, state estimation, and control. I bring this foundation to robot learning, combining physical understanding with data-driven policies for dexterous manipulation.
Selected work
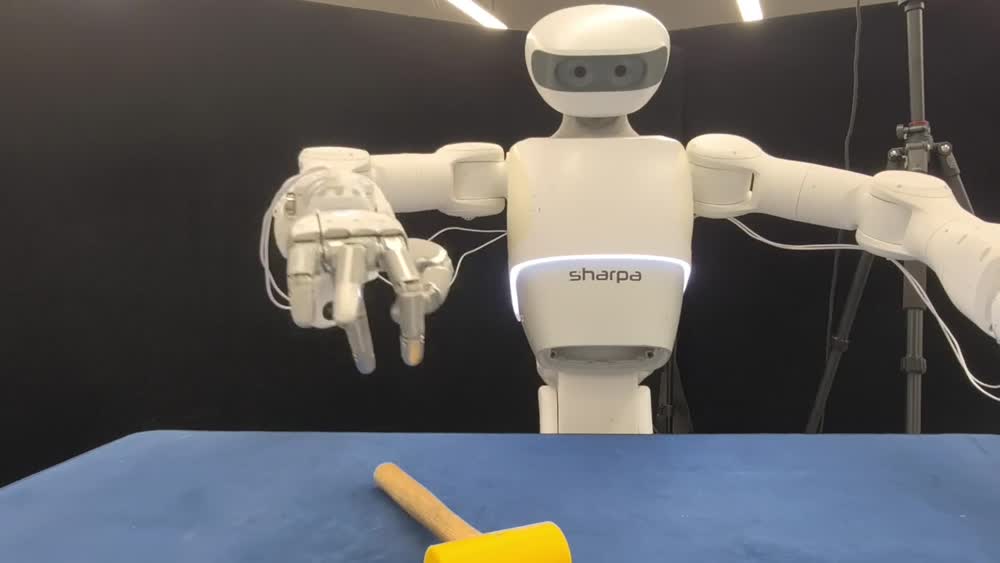
Touch, demonstrations, and learned skills for dexterous robots.
An RL-trained in-hand copilot assists both human data collection and robot execution. MoDE-VLA brings force and tactile feedback into a vision-language-action model for bimanual tasks.
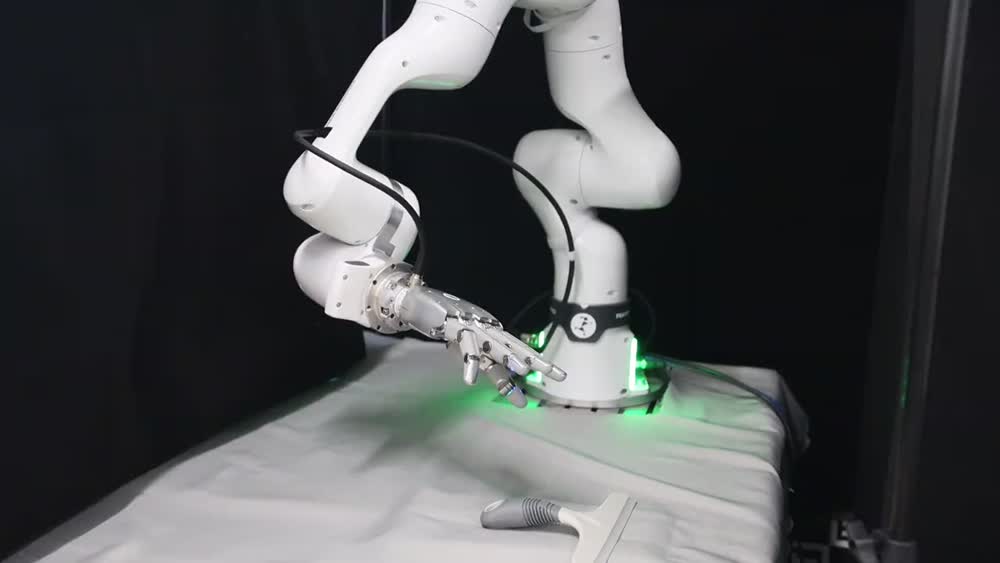
Geometry & state estimation
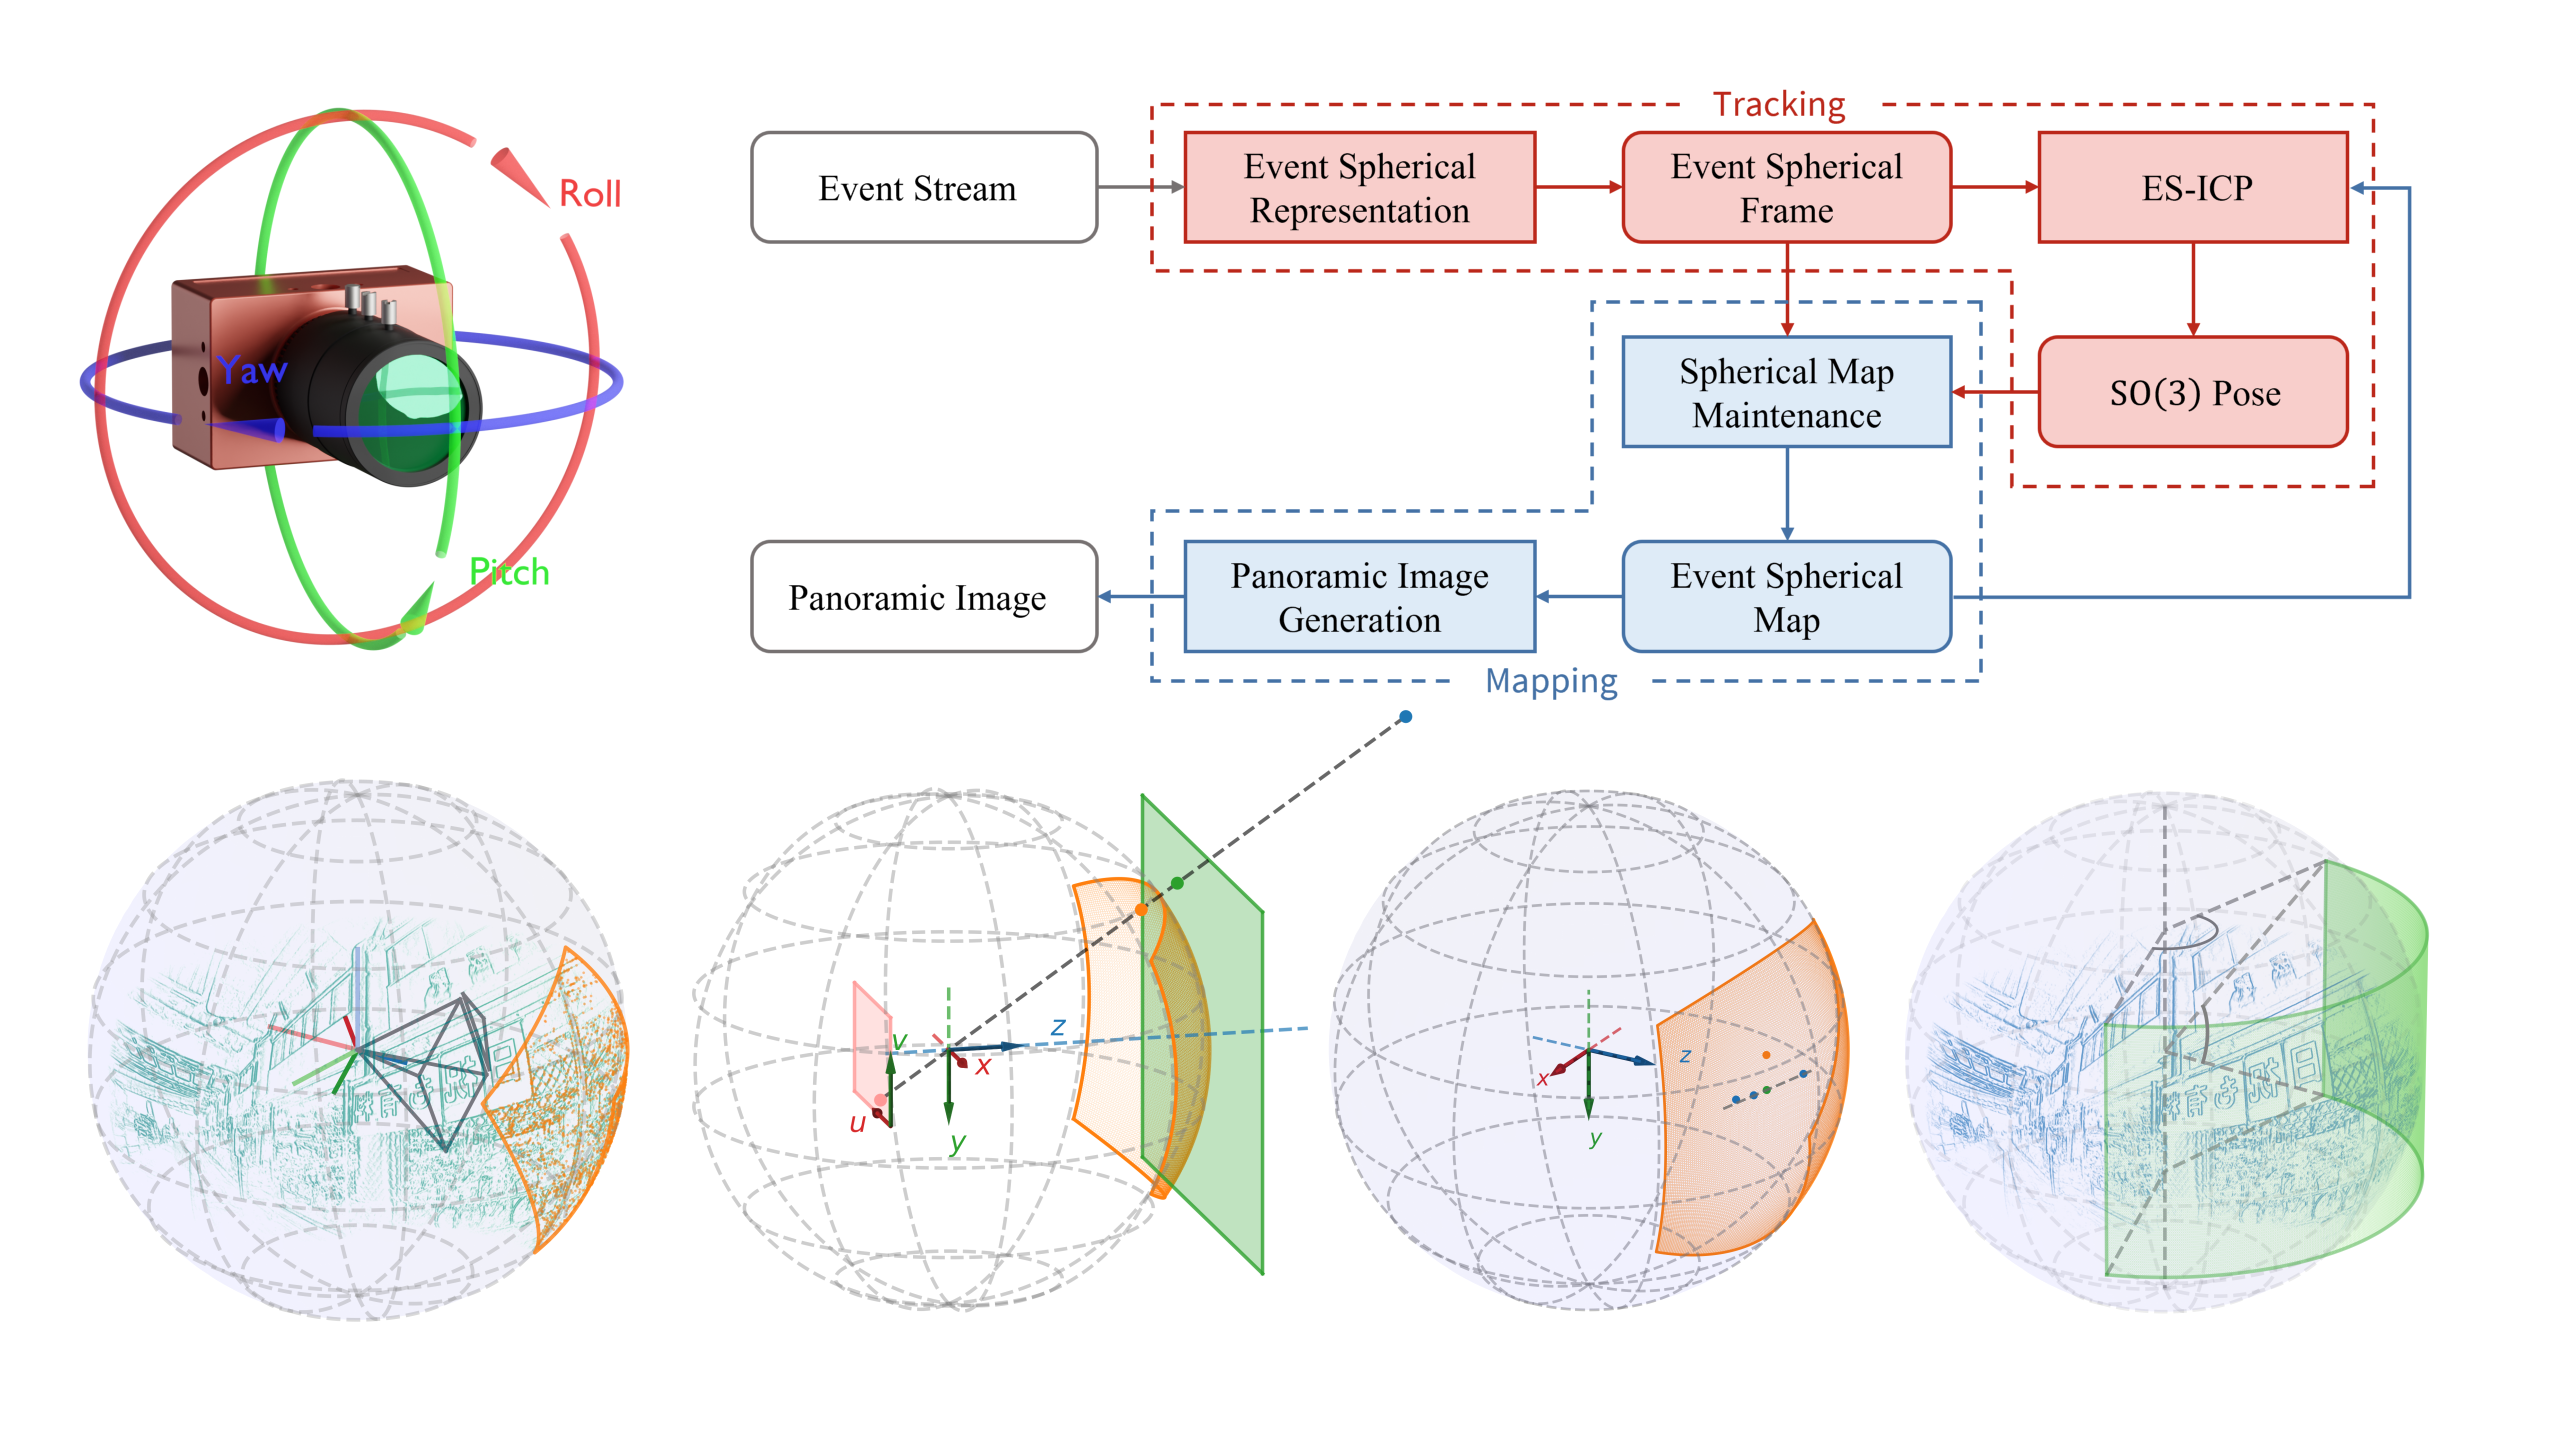
Reliable interaction starts with understanding motion and geometry. My earlier work develops nonlinear optimization methods for rotational odometry, mapping, and sensor calibration, using event cameras and complementary sensors.
Background
Years of research and engineering across geometric estimation, control, and learning, grounded in working robotic systems.
Experience & educationDexterous manipulation & tactile robot learning
The University of Hong Kong
Research and engineering internships
Get in touch
If you're interested in rigorous, high-quality physical AI research, or exploring research opportunities at Sharpa, I'd be glad to connect.